Automated Vertical Farming with Robotics and Computer Vision
A vertical farming system combining robotics, computer vision and sensors to automate farming operations.
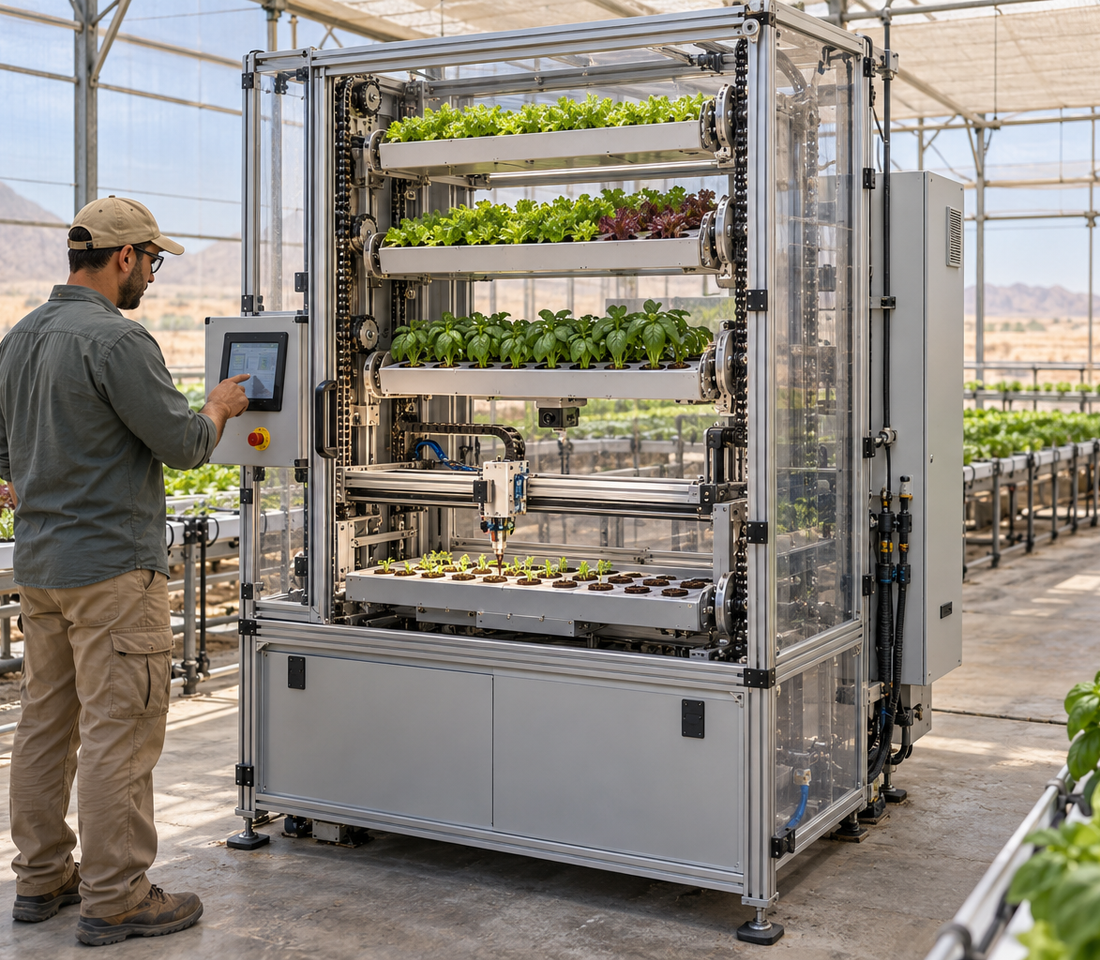
In arid regions, crop production must contend with water scarcity, limited arable land and challenging climatic conditions. Vertical farming makes use of height, but coordinating seeding, irrigation, monitoring and harvesting remains complex. This project aims to bring these functions together in a compact automated system controlled through a single interface.
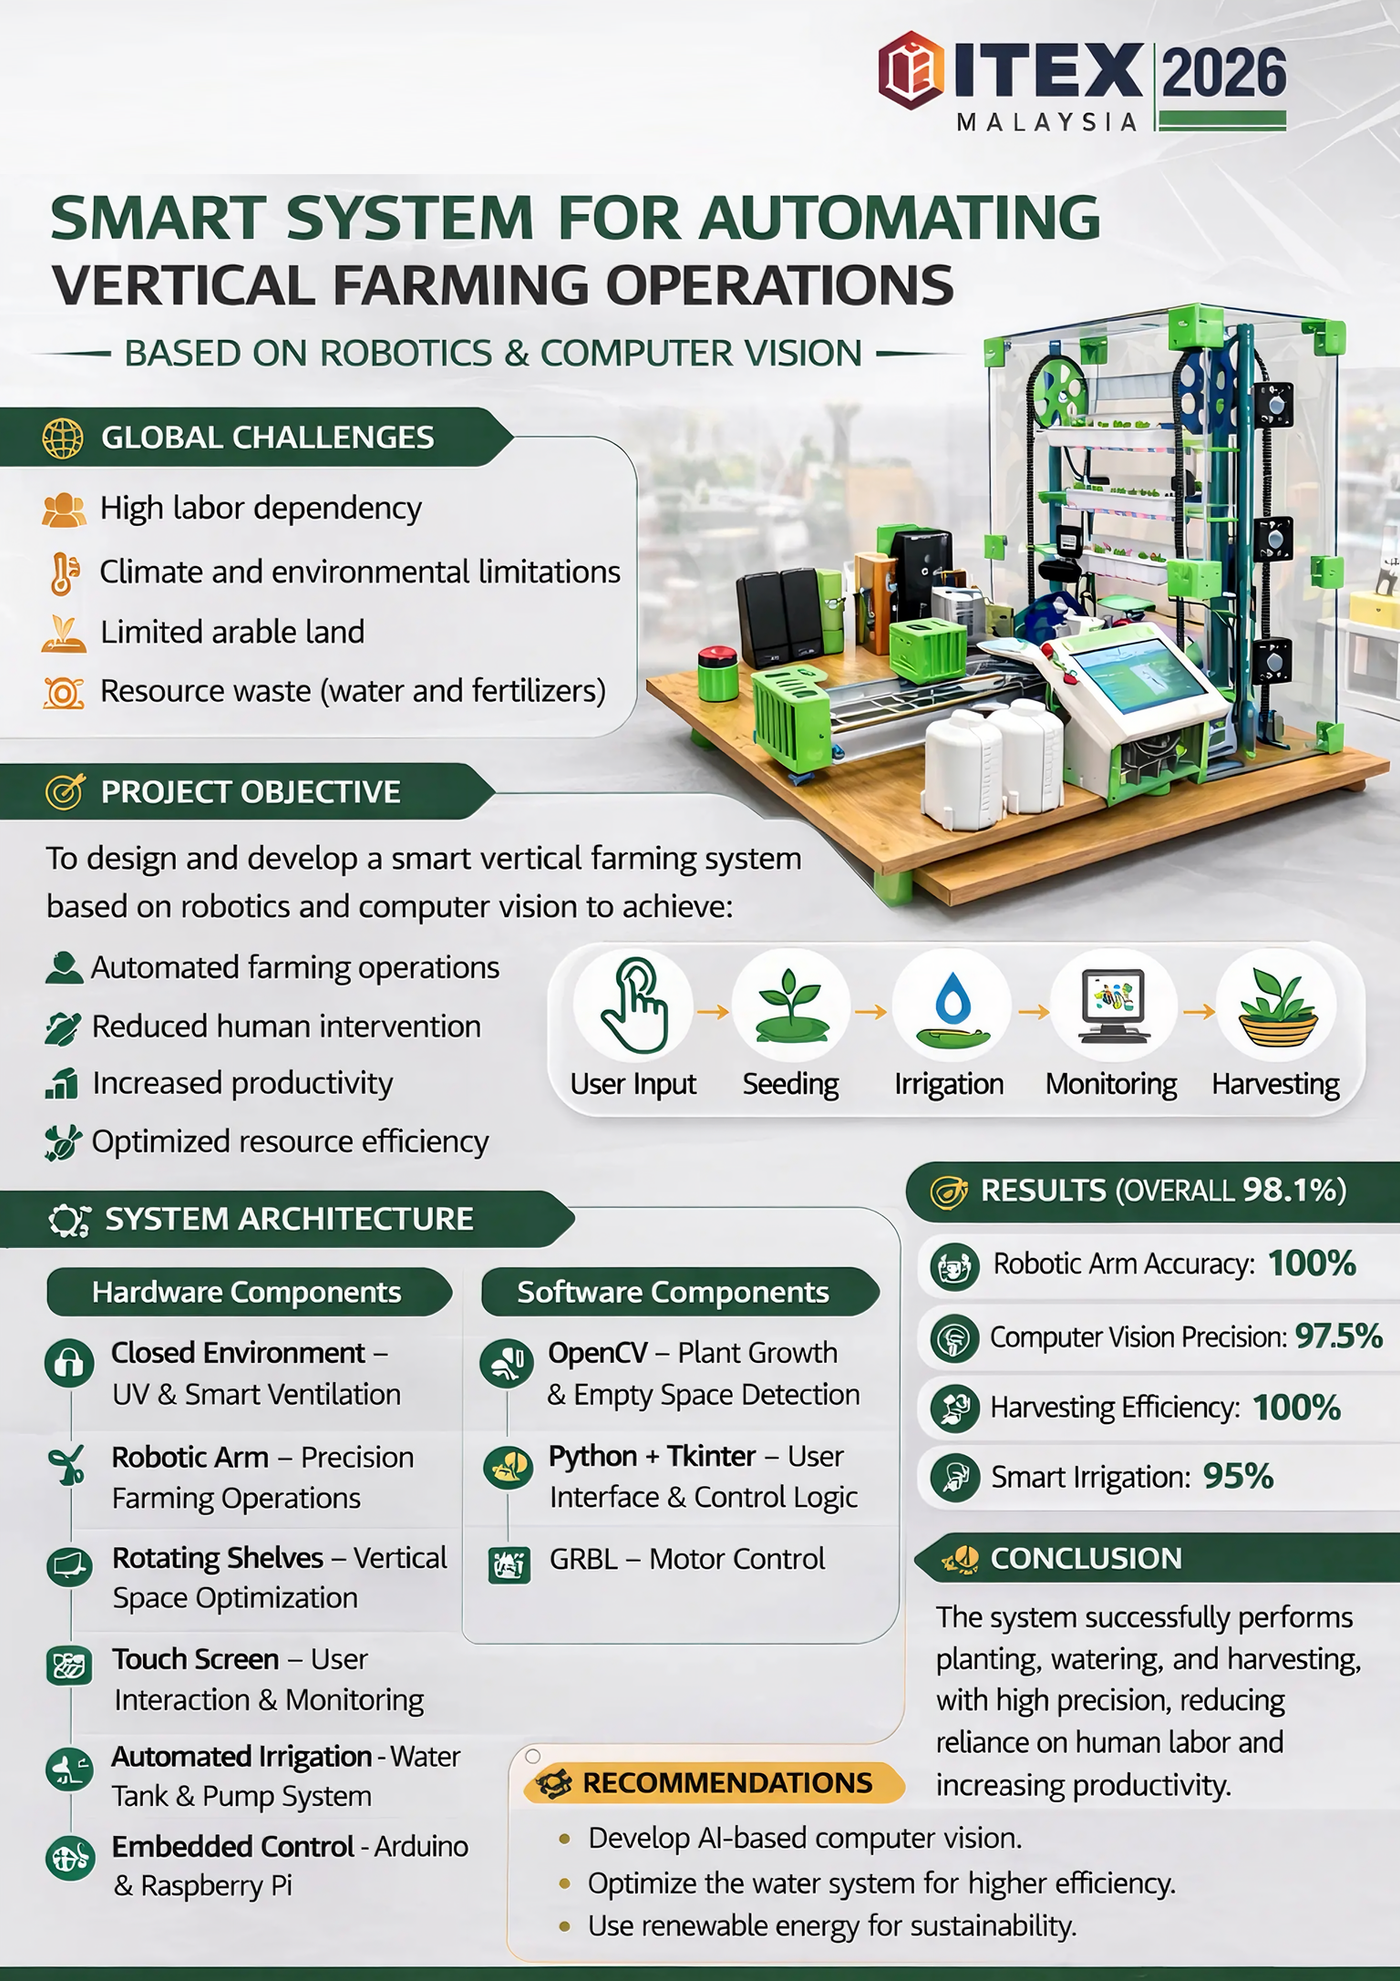
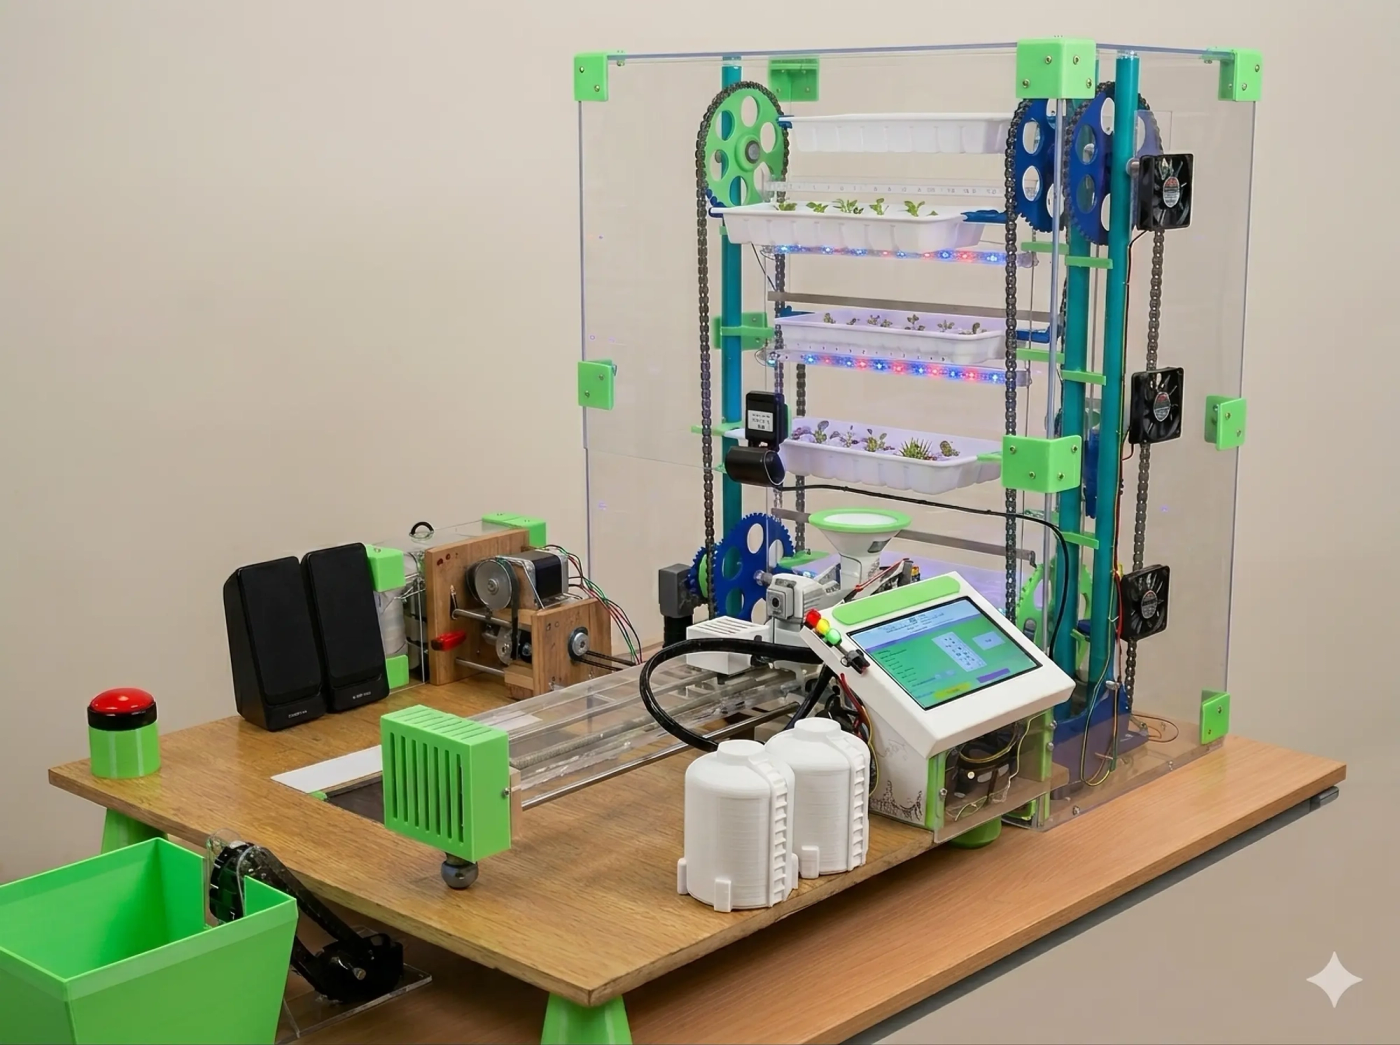
The project combines rotating vertical growing shelves with a two-axis robotic mechanism. Shelf rotation brings growing areas within reach of the mechanism, which moves to programmed coordinates to perform farming tasks.
A Raspberry Pi handles image processing and the user interface, while an Arduino controls the motors and acquires sensor data. Computer vision developed with OpenCV supports planting-location detection and growth monitoring. The system aims to automate the growing cycle, from seeding to harvesting, within a controlled enclosure.
- 01ConfigurationThe user selects growing locations and tasks through the graphical interface.
- 02Positioning and seedingThe shelves present the target area, and the robotic mechanism positions itself to distribute seeds.
- 03IrrigationThe system adjusts watering using sensor data and growing parameters.
- 04Plant monitoringImages and environmental measurements support growth monitoring and available-location detection.
- 05HarvestingThe system is designed to identify mature plants and collect them using the robotic mechanism.
| Processing | Raspberry Pi and Python programming. |
|---|---|
| Sensors | Growing-medium moisture, temperature and air-humidity measurements. |
| Interface | Graphical interface developed with Tkinter. |
| Design | Mechanical modelling in Solidedge. |
The project in pictures
Next steps
- Evaluate the system across multiple growing cycles and plant species.
- Measure water consumption, energy use and the time required for each task.
- Improve growth-stage detection and explore machine-learning-based disease identification.
- Explore solar power and scaling to a larger production capacity.
Interested in this prototype?
Partnership, further testing or industrialisation with C2S Engineering: let's talk.